
Gremsy Gimbal Camera
This article describes how to set up and configure Gremsy Camera Gimbals with XBLink.
Gremsy IP cameras/gimbals can communicate with XBLink via the Ethernet protocol to stream video and telemetry.
Hardware Setup
We support 2 methods to connect it to XBLink as below:
Method 1: Connect directly to the ETH1 port of XBLink Duo.

Method 2: Using USB to Ethernet Adapter. (In case ETH1 port of XBLink is occupied)

Method 1: Connect to the ETH1 port of XBLink Duo
The simplest way to connect a Gremsy Gimbal Camera to XBLink Duo is to use its ETH1 port. You just need to plug in the wire according to the instructions below.


Finally, power up XBLink Duo and the Gremsy Gimbal.
Method 2: Using a USB to Ethernet Adapter
If you intend to use both the remote control and Gremsy Gimbal Cameras, we recommend that you use the USB to Ethernet Adapter to connect to the USB port of the XBLink.
You can connect Gremsy Gimbal Cameras to USB port of XBLink Duo via USB to Ethernet Adapter as below

Finally, power up XBLink Duo and the Gremsy Gimbal.
Configuration
XBStationPilotApp
If you are using the ETH1 port of XBLink Duo (Method 1), please open XBStationPilotApp and configure the Dashboard tab and the Gimbal tab as below:
Open the XBStationPilotApp and configure the settings as follows:
Source Type: GREMSY_VIO
Ethernet: eth1 or eth2
IP Address: 192.168.144.240

Then click the Turn on button. Once the connection is successful, you will be able to see the streaming data appear.

Second, navigate to the Gimbal tab, and configure the Gimbal Model and Gimbal IP as below:
Gimbal Model: GREMSY_VIVO
Gimbal IP: 192.168.144.240

Payload Plus
Finally, please open the Payload Plus Application and configure the Connection tab as below:
Target IP: Same as the Bind Address value from XBStationPilotApp. (This IP tells Payload Plus the exact network address where PilotApp is hosting the gimbal control and telemetry data, allowing the two applications to communicate).
RTSP URL: Same as the RTSP URL value from XBStationPilotApp. (This URL provides the direct path for Payload Plus to pull and display the live video feed from your Gremsy camera).

Ground Station
QGroundControl
Open QGroundControl, Change Source section to UDP H.265 Video Stream as below.

Mission Planner
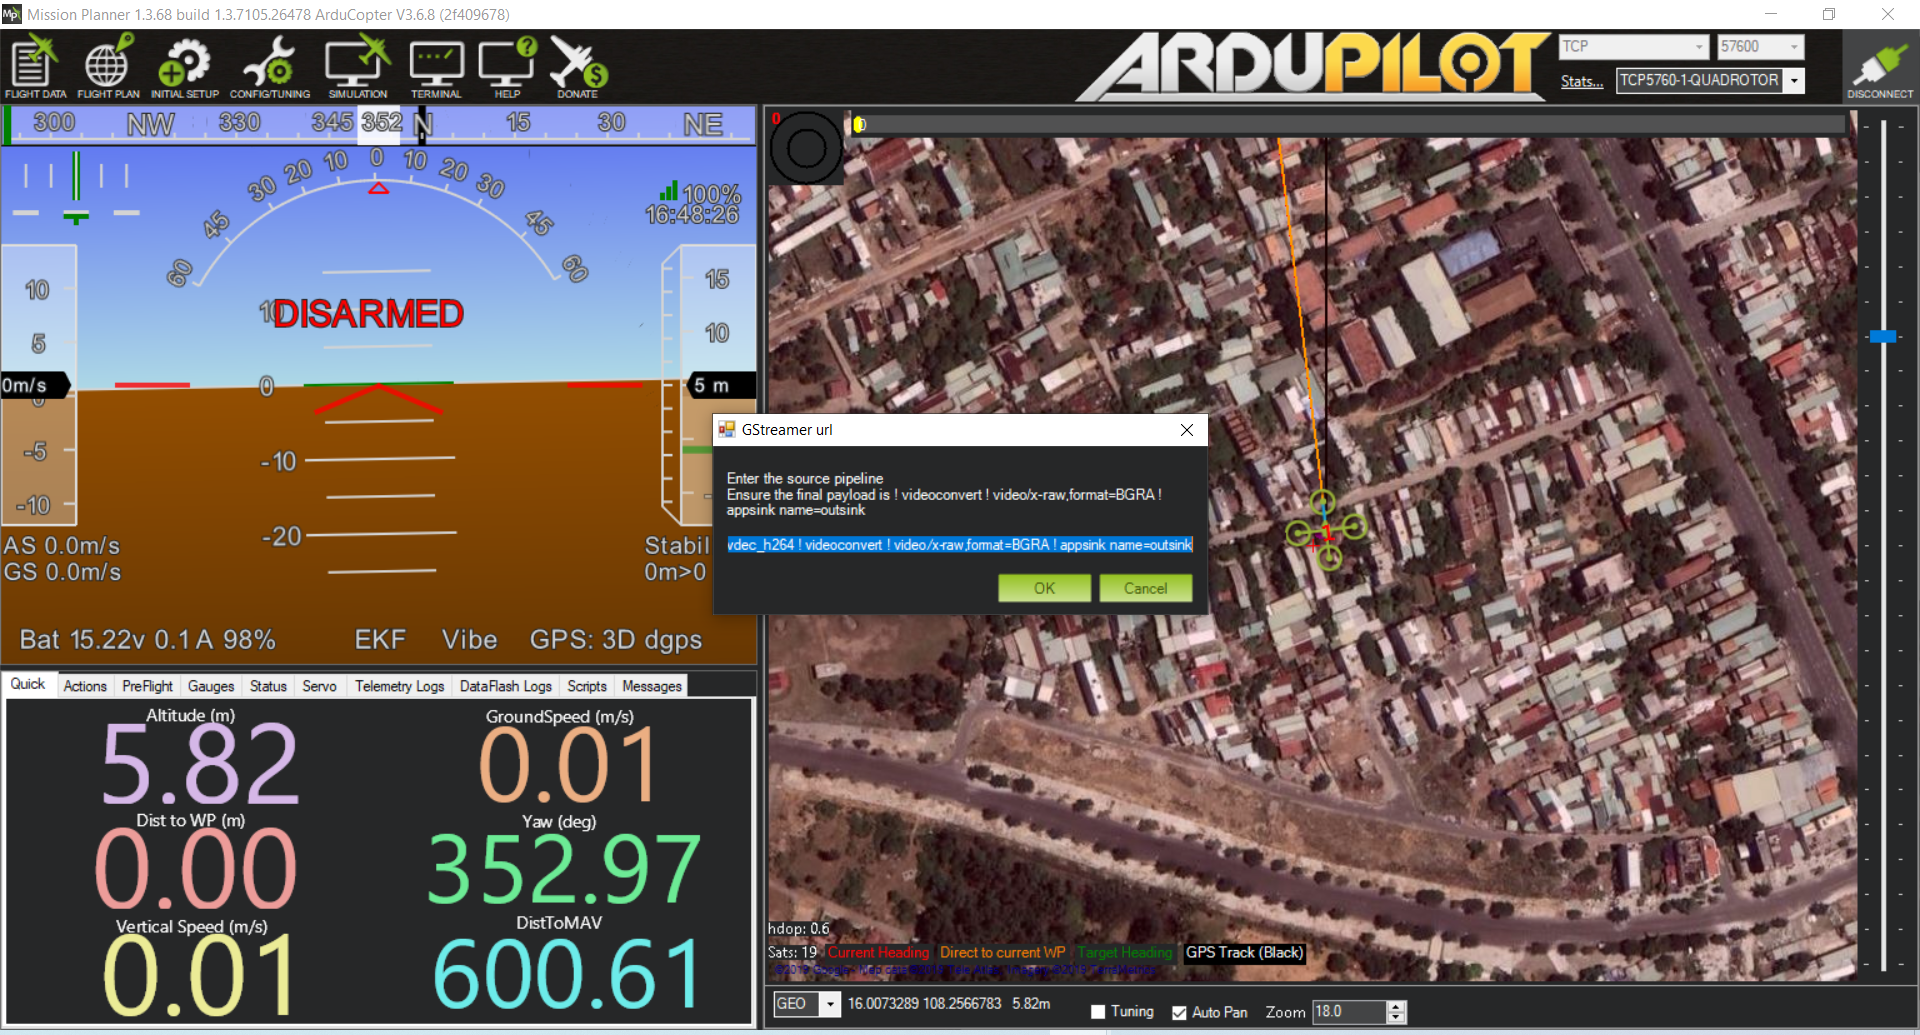
At the Video HUD area, Right Click -> Video -> GStreamer Stop as below instruction

At the Video HUD area, Right Click -> Video -> Set GStreamer source -> input GStreamer URL:
udpsrc port=5601 caps = "application/x-rtp, media=video, clock-rate=90000, encoding-name=H265, payload=96" ! rtpjitterbuffer ! rtph265depay ! avdec_h265 ! videoconvert ! video/x-raw,format=BGRA ! appsink name=outsink

After the installation is complete, restart the MissionPlanner ground station to display the following interface.
Video tutorial
For more information see video as below
Last updated